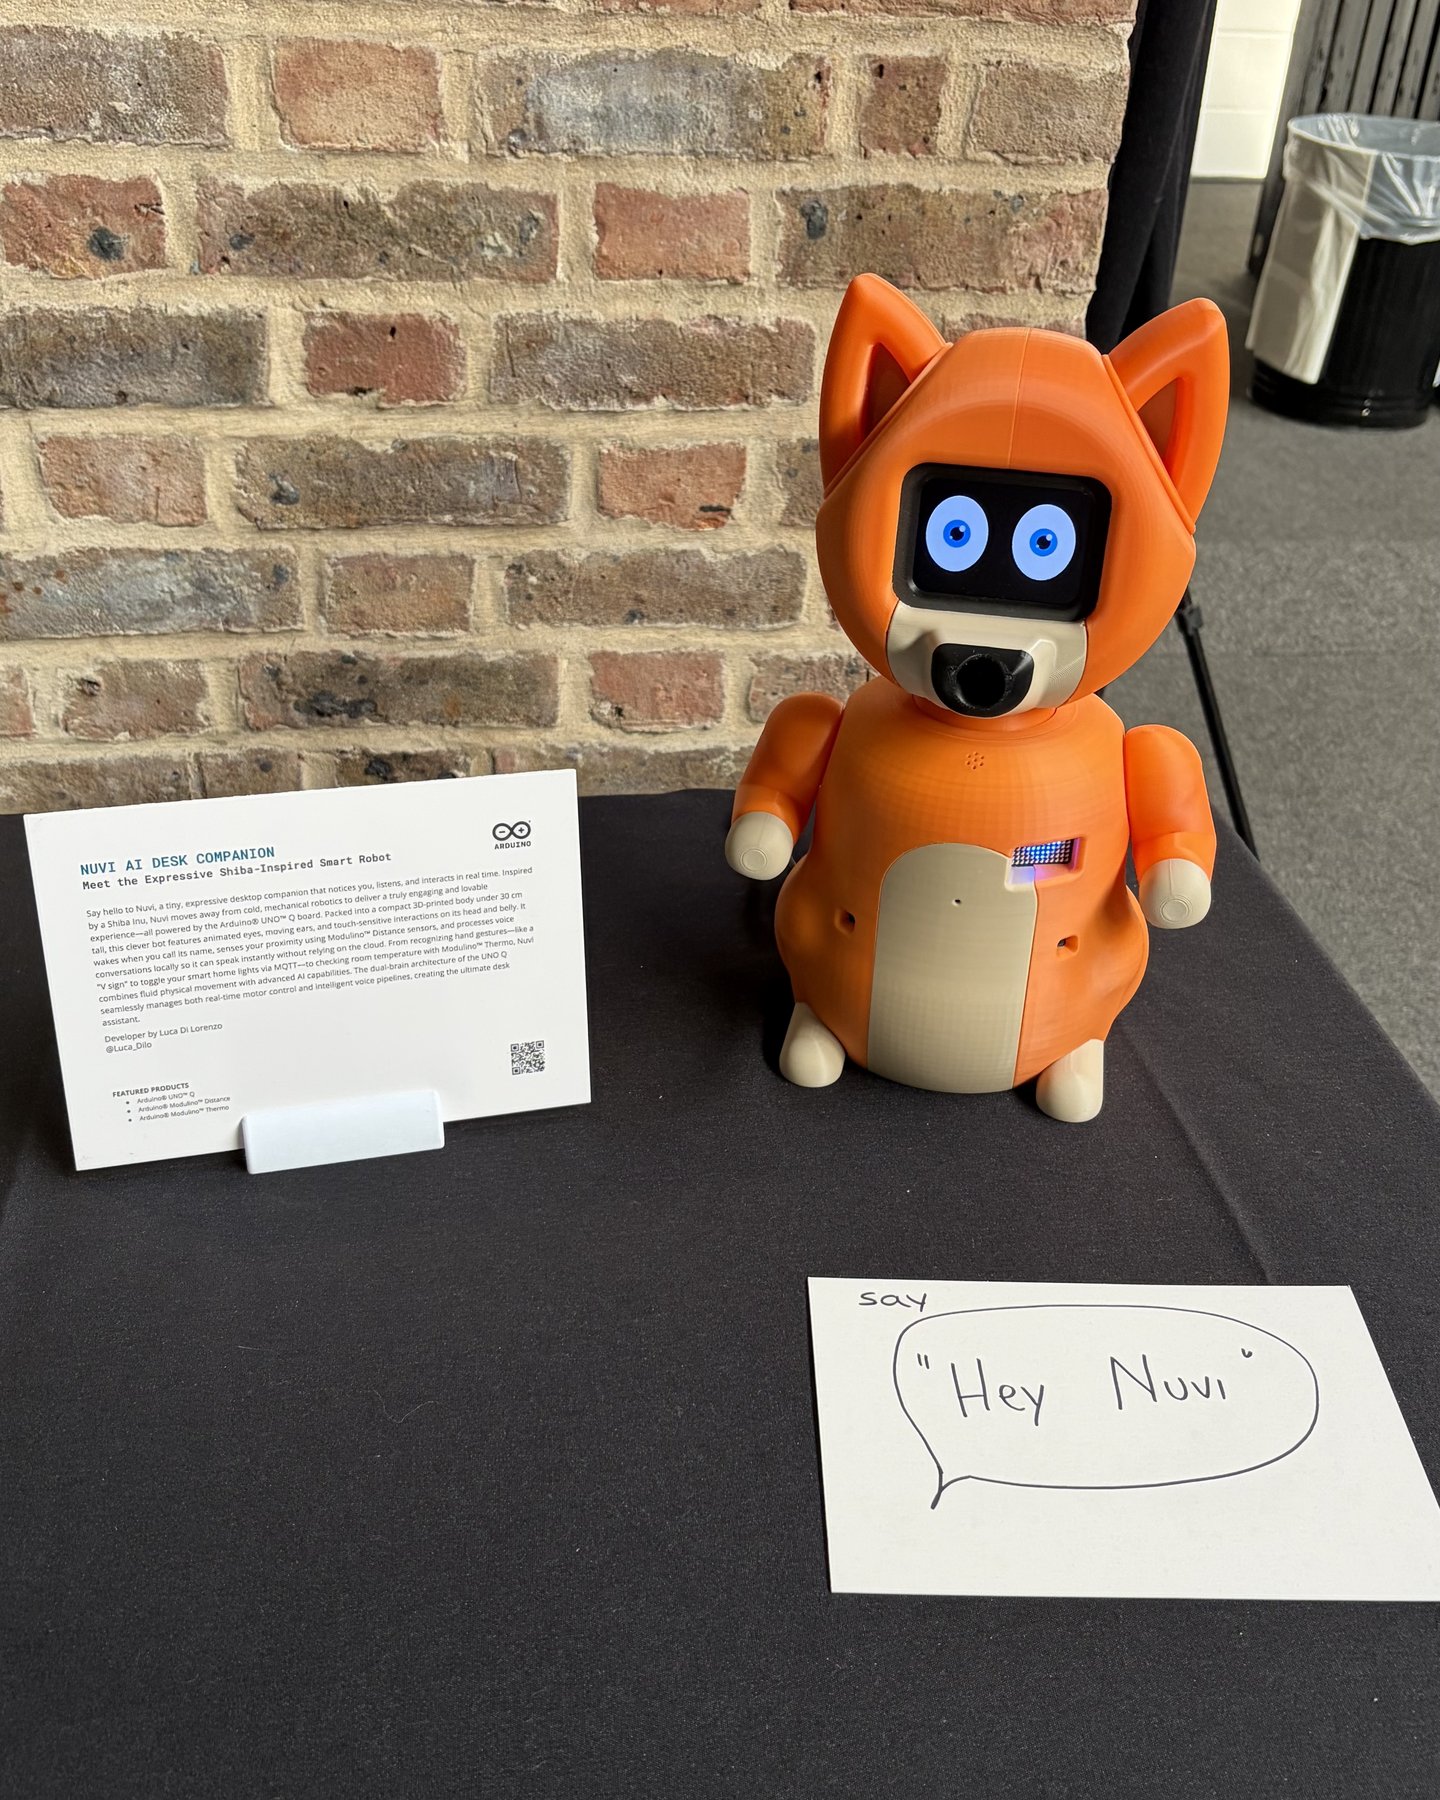
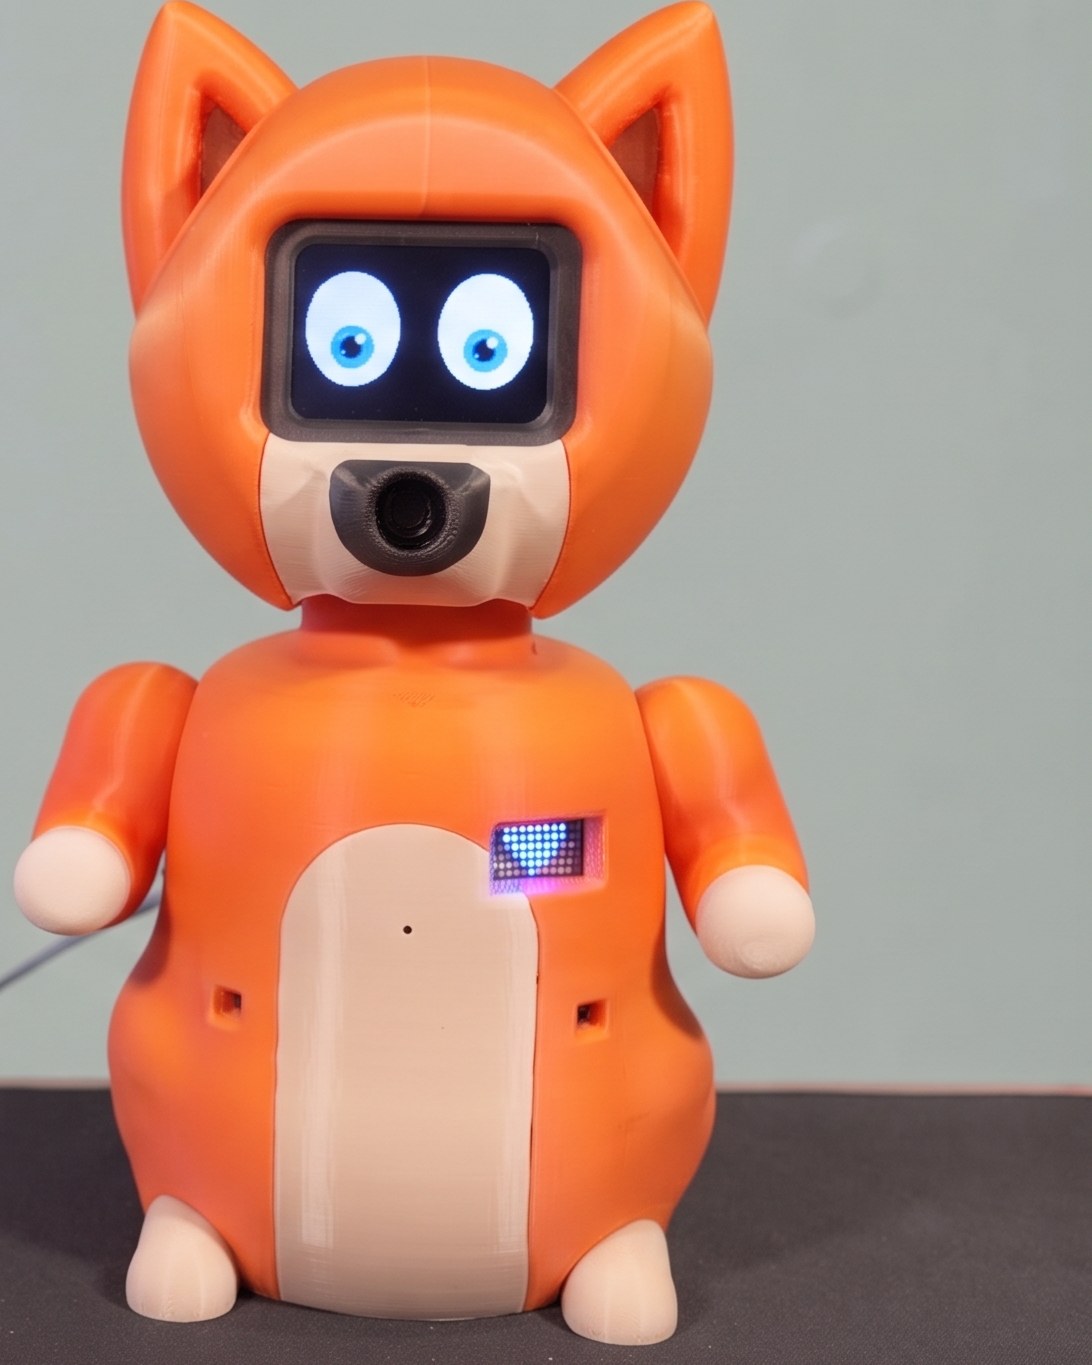
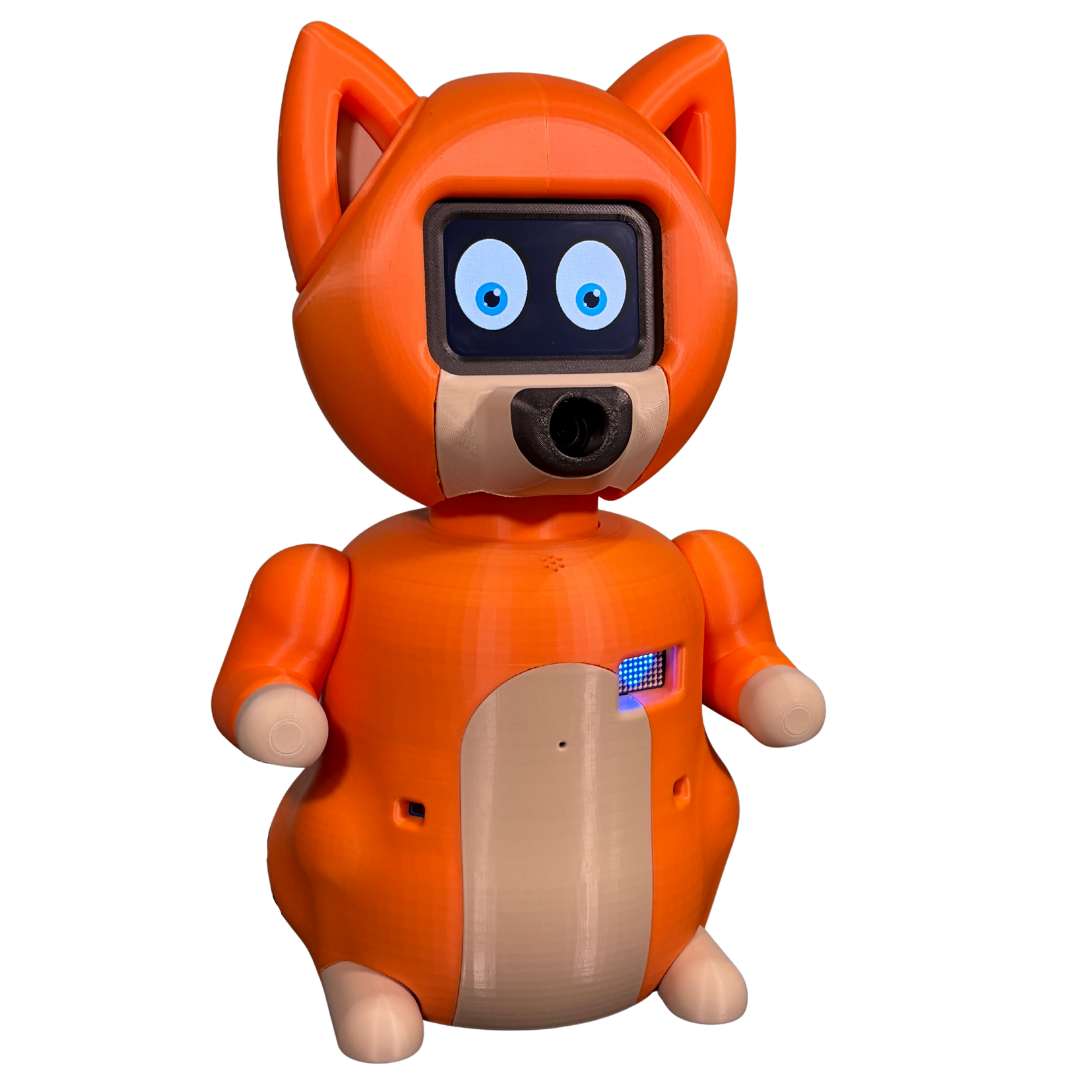
Body
bodyThe central shell everything else hangs from: it carries the leg servos, the electronics holder and the two covers. It is the largest printed piece and the one that sets every tolerance downstream.
MaterialPLA+
Layer0.2 mm
Infill25%
Print time14h 30m
Supportsno
Printed in one piece to avoid a seam across the part that takes the most load.
Front body cover
front_cover_bodyCloses the chest and gives the robot its front profile. Removable without tools, because the electronics behind it have to be reached during calibration.
MaterialPLA+
Layer0.2 mm
Infill15%
Print time4h 10m
Supportsyes
The second touch sensor is behind this panel — the belly. Thin wall here too, and no infill in the sensing area, so a hand is read reliably.
Back body cover
back_cover_bodyThe rear half of the shell. Curved on both axes, so it is the part where layer height shows most and where a finer setting was worth the extra hours.
MaterialPLA+
Layer0.16 mm
Infill15%
Print time5h 45m
Supportsyes
Bottom cover
body_bottom_coverCloses the underside of the body and keeps dust out of the servo bay. It is the panel that comes off first when something has to be checked.
MaterialPLA+
Layer0.2 mm
Infill15%
Print time1h 20m
Supportsno
Servo bracket
servo_bracketThe standard bracket that holds a servo to the structure, repeated wherever one is mounted. Small, printed many times, and the first part revised when a servo changed model.
MaterialPETG
Layer0.16 mm
Infill50%
Print time0h 55m
Supportsyes
Servo driver board
pca9685The board that drives the four servos of ears and arms: sixteen PWM channels on one I²C bus, so the UNO Q sends positions and this one keeps the pulses steady. The two neck servos are not on it: they are serial, and have a board of their own.
Left arm servo
servo_arm_sxOne of the four metal-gear micro servos driven by the PCA9685: this one moves the left arm, independently from the other, which is what makes the dance possible. Metal gears instead of plastic, because ears and arms are the parts people grab.
ModelMetal-gear micro servo
Right arm servo
servo_arm_dxOne of the four metal-gear micro servos driven by the PCA9685: this one moves the right arm, independently from the other, which is what makes the dance possible. Metal gears instead of plastic, because ears and arms are the parts people grab.
ModelMetal-gear micro servo
Distance sensor, chest
modulino_distanceA time-of-flight distance sensor in the Modulino form factor. The two of them sense presence: Nuvi wakes when you come close, and drops any voice that does not come from someone near enough — if nobody is there, it does not even listen.
ModelArduino Modulino Distance
Distance sensor, side
modulino_distance_1A time-of-flight distance sensor in the Modulino form factor. The two of them sense presence: Nuvi wakes when you come close, and drops any voice that does not come from someone near enough — if nobody is there, it does not even listen.
ModelArduino Modulino Distance
Neck servos
main ×2The two serial servos that move the head: one pans, one tilts. Serial bus instead of PWM, so they sit on one cable and report their position, and the neck could be drawn around them with no visible cables or levers.
Chest matrix
modulino_led_matrixThe small status icons on the chest: thinking, talking, sleeping. A Modulino, so it shares the same bus as the distance and temperature sensors.